🎉 I started as a postdoctoral researcher at the GRASP Lab at UPenn.
I just started as a postdoctoral researcher at the GRASP Lab at the University of Pennsylvania, under the supervision of Prof. Kostas Daniilidis!
 ☕️
Postdoctoral Researcher & Incoming Assistant Professor
I am a postdoctoral researcher at the GRASP Lab, University of Pennsylvania, working under the supervision of Prof. Kostas Daniilidis. In March 2027, I will be joining the Department of Mechanical Engineering at the National University of Singapore (NUS) as an Assistant Professor.
Ph.D. Computer Vision and Robotics
University of Zurich
MSc Mechanical Engineering
ETH Zurich
BSc Mechanical Engineering
ETH Zurich
I am a postdoctoral researcher at the GRASP Lab under the supervision of Prof. Kostas Daniilidis working on the intersection of computer vision, robotics and machine learning with and without event cameras.
My research focuses on event-based sensing, and recently extended from vision-based (i.e., event cameras) to IMUs as part of my recent work on Lie Events for IMU-based navigation, and event-based computation in the embedding space via asynchronous neural networks. At NUS, I will be starting a research group working broadly at the intersection of robotics, computer vision, machine learning, and event-driven computation. A central goal of the group will be to develop intelligent systems that perceive, predict, and act efficiently in dynamic, high-speed environments, with a particular interest in event-driven and adaptive approaches.
Please reach out to collaborate!
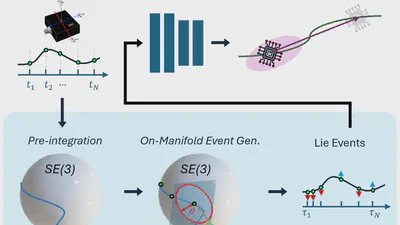
Note This work extended event-based sampling to IMU-based navigation opening the door to new event-based sensing paradigms!
Note This work lead to me winning the UZH Annual Award, which is awarded to the best Ph.D. in the department of Informatics!
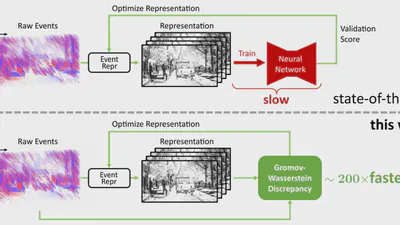
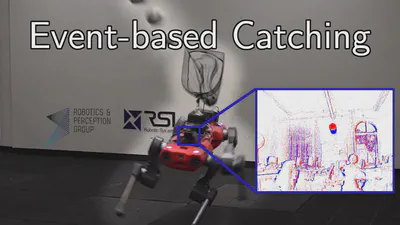
Note Here we explore the advantages of using event cameras to catch high-speed objects at up 15 m/s with the quadrupedal robot ANYmal. Our paper “Event-based Agile Object Catching …
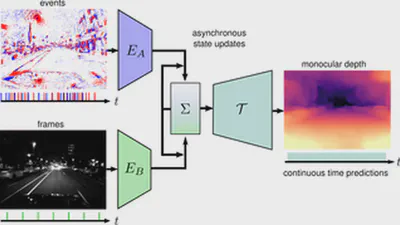
Note The work by Michelle Rüegg that contributed to the paper “Combining Events and Frames using Recurrent Asynchronous Multimodal Networks for Monocular Depth Prediction”, …
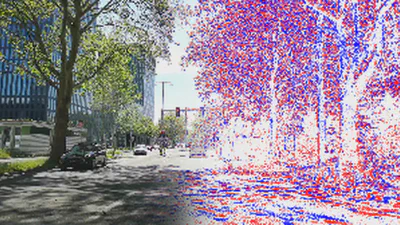
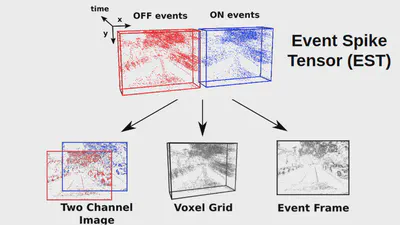
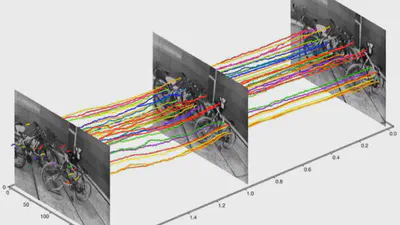
Note This paper received an oral at ECCV 2018 and was invited as a journal extension at IJCV!
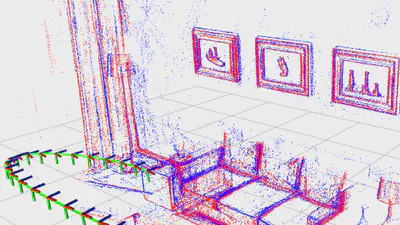
A talk discussing event-based sensing for cameras and IMU, and emergent equivariant properties.
A talk discussing algebraic and geometric properties of event data.
A talk discussing deep learning techniques for efficient event processing.
A talk discussing deep learning techniques for efficient event processing.
A talk discussing deep learning techniques for efficient event processing..
I just started as a postdoctoral researcher at the GRASP Lab at the University of Pennsylvania, under the supervision of Prof. Kostas Daniilidis!
I successfully defended my Ph.D. thesis titled “Efficient, Data-driven Perception with Event Cameras”.