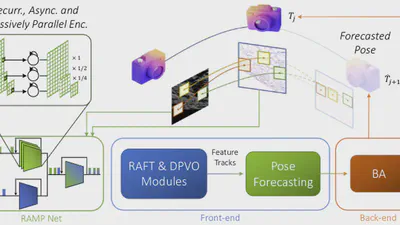
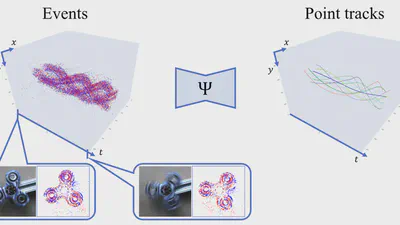
Neural Events: Discrete Asynchronous Autoencoders for Event-Based Vision
Roberto Pellerito
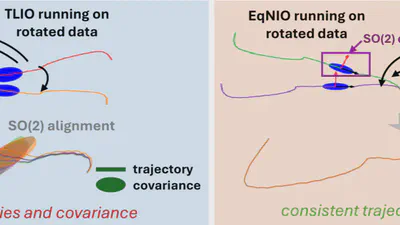
EqNIO: Subequivariant Neural Inertial Odometry
Royina Karegoudra Jayanth*
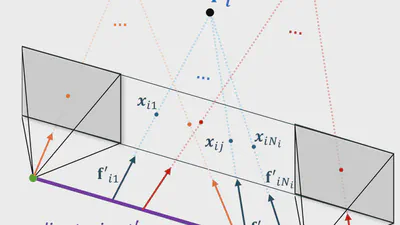
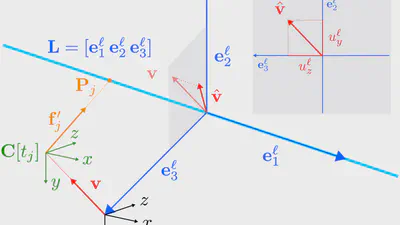
An N-Point Linear Solver for Line and Motion Estimation with Event Cameras
Note This paper lead to an oral at CVPR 2024 in Seattle!
Ling Gao*
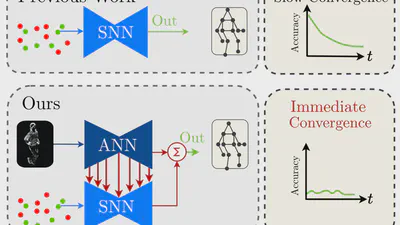
A Hybrid ANN-SNN Architecture for Low-Power and Low-Latency Visual Perception
Note The work by Asude Aydin that contributed to the paper “A Hybrid ANN-SNN Architecture for Low-Power and Low-Latency Visual Perception” at a CVPR Workshop 2024 lead to a UZH …
Asude Aydin
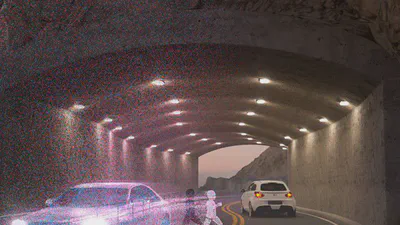
Low Latency Automotive Vision with Event Cameras
Note This work lead to me winning the UZH Annual Award, which is awarded to the best Ph.D. in the department of Informatics!
Daniel Gehrig
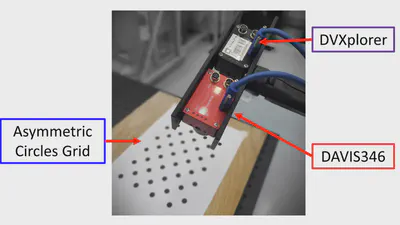
E-Calib: A fast, robust, and accurate calibration toolbox for event cameras
Mohammed Salah