A 5-Point Minimal Solver for Event Camera Relative Motion Estimation
Note This paper lead to an oral at ICCV 2023 in Paris!
Ling Gao
Event-based Agile Object Catching with a Quadrupedal Robot
Note Here we explore the advantages of using event cameras to catch high-speed objects at up 15 m/s with the quadrupedal robot ANYmal. Our paper “Event-based Agile Object Catching …
Benedek Forrai*
Pushing the Limits of Asynchronous Graph-based Object Detection with Event Cameras
Daniel Gehrig
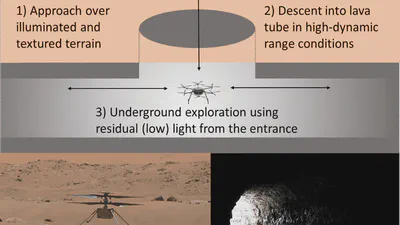
Exploring Event Camera-based Odometry for Planetary Robots
Florian Mahlknecht
Time Lens++: Event-based Frame Interpolation with Parametric Non-linear Flow and Multi-scale Fusion
Note This work appeared in IEEE Spectrum, and lead to a patent with Huawei RC Zurich!
Stepan Tulyakov
Multi-Bracket High Dynamic Range Imaging with Event Cameras
Note This paper lead to the following patent with Huawei RC Zurich!
Nico Messikommer
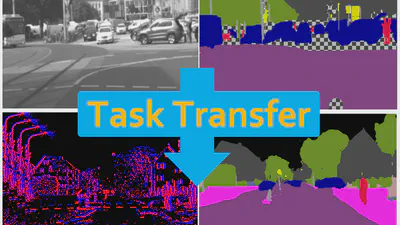
ESS: Learning Event-based Semantic Segmentation from Still Images
Zhaoning Sun*
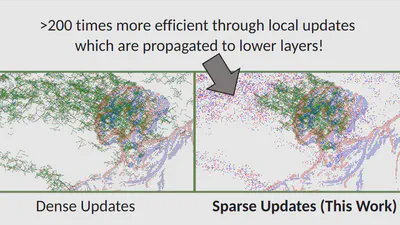
AEGNN: Asynchronous Event-based Graph Neural Networks
Simon Schaefer*