RoSHI: A Versatile Robot-oriented Suit for Human Data In-the-Wild
Wenjing Margaret Mao
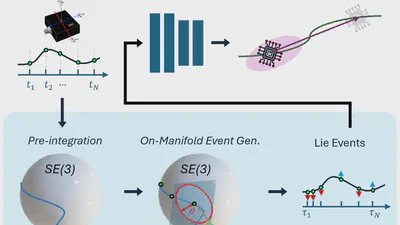
Note This work extended event-based sampling to IMU-based navigation opening the door to new event-based sensing paradigms!
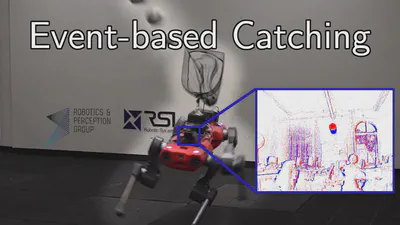
Note Here we explore the advantages of using event cameras to catch high-speed objects at up 15 m/s with the quadrupedal robot ANYmal. Our paper “Event-based Agile Object Catching …
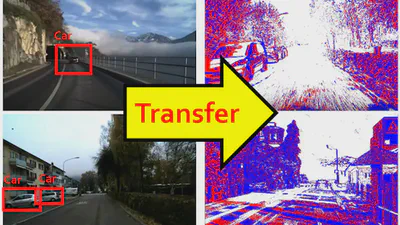
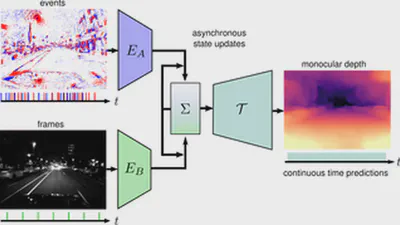
Note The work by Michelle Rüegg that contributed to the paper “Combining Events and Frames using Recurrent Asynchronous Multimodal Networks for Monocular Depth Prediction”, …
I gave the Guest Lecture "Learning from Internet Data" for the course "Real-World Robot Learning" at The University of Pennsylvania. The course covers vision and language …